Pingyu Xiang
向 平宇

I am a Ph.D. candidate in Robotics at Zhejiang University, advised by Prof. Haojian Lu. My research focuses on magnetic sensing and localization, medical robotics, and intelligent robotic systems.
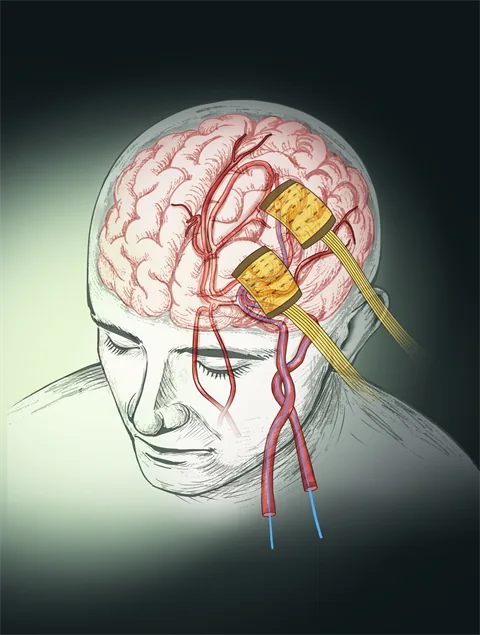
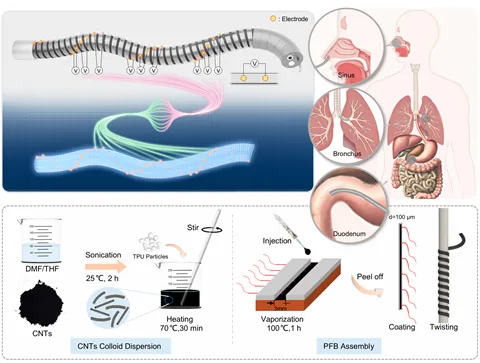
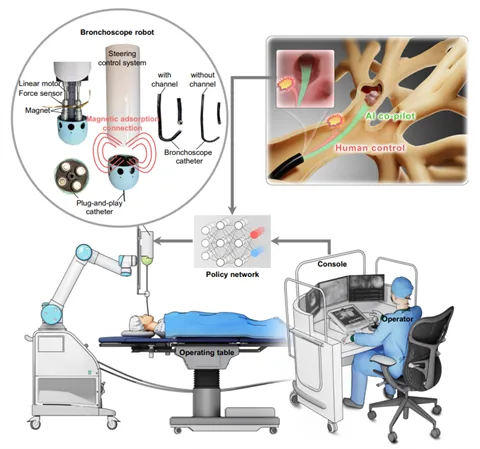
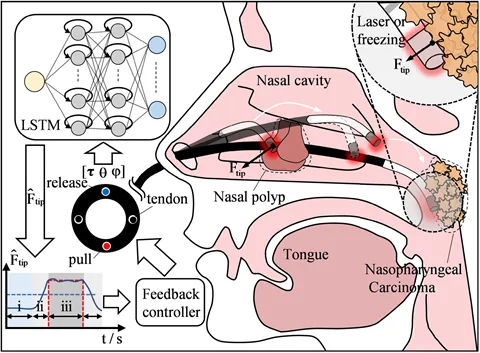
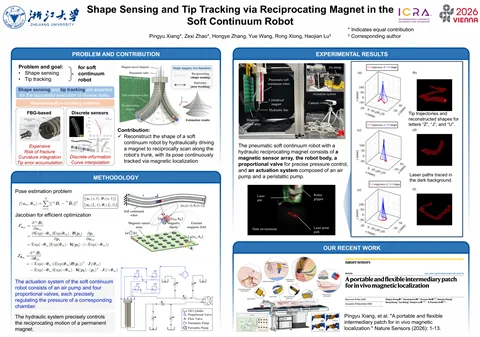
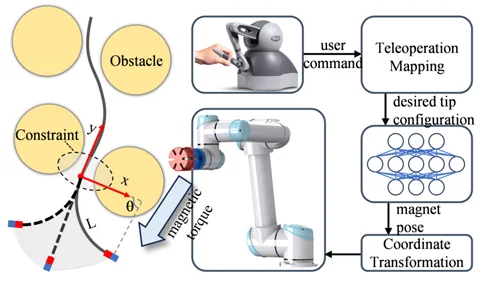
I am particularly interested in developing flexible, reconfigurable, and uncertainty-aware sensing technologies for robotic perception and interaction in complex environments. To date, these efforts have led to publications in journals and proceedings including Nature Sensors, IEEE T-RO, IEEE T-ASE, ICRA and IROS. My current work explores magnetic tracking, continuum robot shape sensing, and human–robot interaction, with applications in minimally invasive diagnosis and intervention.
My long-term goal is to develop intelligent robotic systems that are clinically meaningful.
Feel free to reach out for research collaboration and intellectual exchange! 😀
news
| May 21, 2026 | Our paper was accepted by Cyborg and Bionic Systems. 🎉 Thanks Xiangyu, Hongye and Fei for their collective effort. Thanks our advisor’s guidance and support. |
|---|---|
| Feb 27, 2026 | Our paper on uncertainty analysis of magnetic localization on SE(3) has been accepted by IEEE T-RO. 🎉 Many thanks to my advisor for the guidance and support! Many thanks to Hongye for his help and collaboration! |
| Jan 31, 2026 | Our paper has been accepted to ICRA 2026. See you in Vienna! 🕺 |
| Dec 11, 2025 | Our paper on in vivo magnetic localization has been accepted for publication in Nature Sensors! 🎉🎉🎉 We sincerely thank our advisors for their guidance and support, and Danying, Hongye, and Guoyao for their dedicated teamwork and collective effort. |
| Jun 30, 2024 | Our paper on shape sensing of the continuum robot was accepted by IEEE RA-L. Congratulations to Hongye! |